Claude Opus 5.5 in Claude Code 2.1.280 + Remotion/HyperFrames skills
skills on · Claude Code 2.1.280 + Remotion/HyperFrames skillsKit: remotion 4.0.532 · 1 of 12 installed skills used in the session
Rendered video (by the agent)
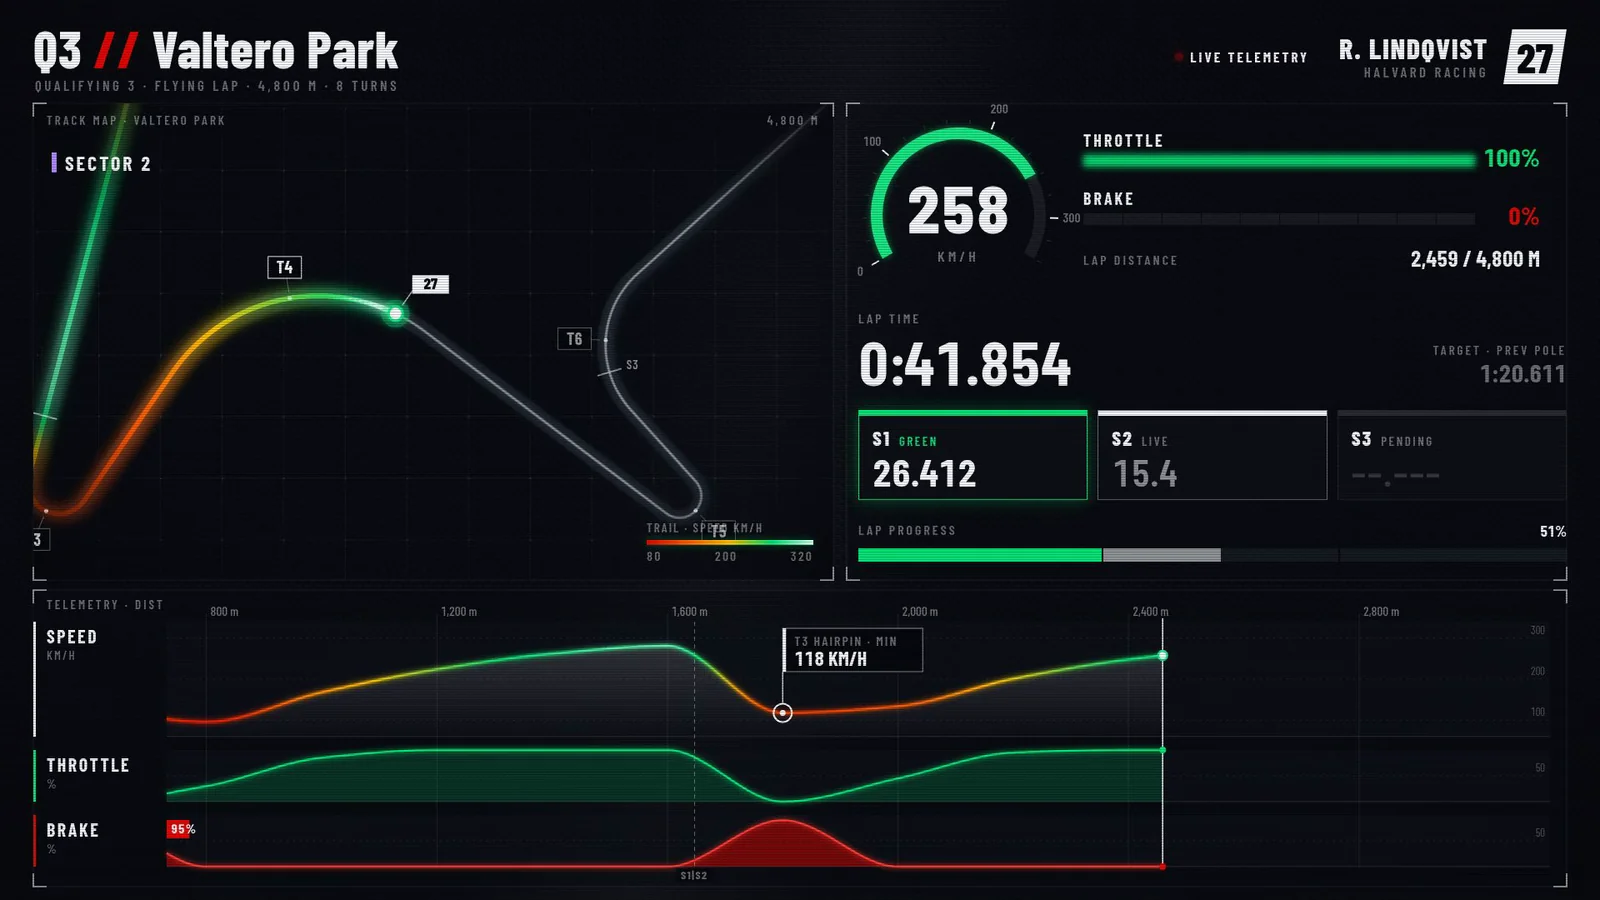
Rendered video (by the agent). This is the finished MP4 saved in the run. Played from a 720p web copy made by this site from the agent's out.mp4; the original file is too large for this host and is kept unchanged on the runs branch. Download video (2.4 MB).
Wall time 26m 08sCost $4.76 estimated
Review
No verdict yet.
The full review
OK. Finished on its own after 26.1 min.
Scores
AI judge
Not scored
No rubric for this prompt
Visitor votes and reviewer grades are not available yet.
- AI judge
- AI judge: the test runner (model claude-opus-5-5), scoring by visual review of the 1600 px render against the pre-registered rubric. No AI-judge score exists for this result: there is no rubric for this prompt, so no score is shown and none is made up.
- Visitors
- Public voting with a blind reveal is coming: you score the output first, then see the other scores.
- Reviewer
- The reviewer's own grade appears here once it is added.
Scores compare results for the same prompt only. AI-judge boards rank runs within one prompt, equal totals sharing a rank; scores from different prompts are never averaged.
Downloads
Files actually published for this run. Original output, site-made previews and post-run conversions are labelled separately.
The exact prompt
as run, 3,505 characters. Every result for this prompt
[Task]
Create a 30-second telemetry visualisation, 1920x1080 at 30 fps, of one qualifying lap by car #27 (driver R. Lindqvist, team Halvard Racing) at the fictional Valtero Park circuit. A track map and live traces run in sync, ending in a delta reveal.

[Scenes]
1. 0-3 s: Darkness. A racing line draws the circuit outline in one stroke, and corner labels T1-T8 pop in. The title "Q3 // Valtero Park" slides in, and three empty trace lanes (Speed, Throttle, Brake) unfold beneath.
2. 3-11 s: Sector 1. The car dot launches, leaving a speed-coloured trail. All three traces draw left to right in lockstep with the dot. A digital speedometer counts live. At T1 the brake lane spikes red and the camera punches in on the corner.
3. 11-19 s: Sector 2. The camera drifts across the map. The trace view auto-scrolls, and the T3 and T5 hairpin minima get annotated callouts. The sector time locks in with a purple flash, marking a personal best.
4. 19-26 s: Sector 3. The car flows through T7 and T8, and the trail completes the loop. The S3 time locks in.
5. 26-30 s: The map zooms out. The three sector tiles assemble into a lap time of 1:20.453, a ghost trace of the previous pole overlays the data, and the delta counts to -0.158 in green. Final text: "Provisional Pole".

[Style]
Palette: #07090D (carbon black), #E10600 (brake red), #00E676 (throttle green), #B388FF (purple best), #F5F7FA (white). Type is a condensed technical sans with tabular figures. Lighting uses glowing strokes, faint carbon-weave texture and scanline sheen. Motion is snappy, with quick ease-out expo, tight springs on tiles and a hard-edged 4-frame stagger.

[Data]
Samples every 200 m (lap 4,800 m), listed as distance m: speed km/h / throttle % / brake %.
0:298/100/0, 200:312/100/0, 400:318/100/0, 600:142/0/95, 800:96/30/0, 1000:168/85/0, 1200:224/100/0, 1400:262/100/0, 1600:281/100/0, 1800:118/0/90, 2000:134/45/0, 2200:201/95/0, 2400:248/100/0, 2600:276/100/0, 2800:291/100/0, 3000:84/0/100, 3200:122/40/0, 3400:188/90/0, 3600:236/100/0, 3800:264/100/0, 4000:172/20/60, 4200:158/60/0, 4400:241/100/0, 4600:289/100/0.
Sectors: S1 26.412 (green), S2 31.087 (purple), S3 22.954 (green). Previous pole: 1:20.611.

[Wow]
- The dot, traces and speedometer are frame-locked to the same distance variable.
- The trail colour is mapped continuously to speed via a gradient.
- Corner punch-in camera moves with motion-blurred trails.
- Odometer-style rolling digits for all timing values.

[Rules]
- Every frame is drawn in code (SVG, canvas, CSS or WebGL). No image files, no image generation, no external assets beyond fonts.
- Deterministic: no unseeded randomness at render time.
- Text must be crisp, spelled correctly and readable at 1080p.
- No hard cuts between scenes: every change is a designed transition.
- Use the dataset exactly. Interpolate smoothly between samples.

[Harness notes] Render the final video to out.mp4 (1920x1080, 30 s). Write everything into the working directory. Remotion 4.0.527 is already installed for you in the current directory: node_modules is pre-installed and read-only, so do not run npm install or create-video, and a remotion.config.ts here already points rendering at the local Chromium. Render the final video yourself to out.mp4 in the current directory (for example npx remotion render <entry file> <composition id> out.mp4). You may render stills or frames and inspect your own output (headless chromium is available at /usr/bin/chromium) and iterate on your own before finishing.
How it was made
Versions saved during the run
2 intermediate outputs, in the order the model wrote them.


Step by step
The prompt, every agent turn and tool call (tool name and a one-line summary; inputs and outputs are not shown), then the final message. The full transcript is 10.6 MB; it is published as a scrubbed, compressed download rather than shown on the page.
Show all 64 steps
Loading the timeline…
Download the full transcript Claude Code session JSONL, 128 KB, gzip. Scrubbed: anything that looks like a key, token, e-mail address or phone number is replaced, and account details and the test machine's file paths are removed.
Cost breakdown
Headline cost $4.76, estimated from the token counts at list price.
| Tokens by type | Tokens | $ per 1M | Cost |
|---|---|---|---|
| Input (uncached) | 122 | $4.00 | $0.0005 |
| Cache write | 300,982 | $5.00 | $1.5049 |
| Cache read | 6,708,363 | $0.20 | $1.3417 |
| Output | 95,604 | $20.00 | $1.9121 |
| of which reasoning | 39,593 | billed as output |
- Total computed from tokens
- $4.7592
- Total reported by the harness
- none
Computed from harness-reported token counts x list prices.
Prices: Project price table (vendor list prices), 2026-09-22.
Run notes
- frozen prompt (written): written 2026-10-03 for MR wave rh (owner ask m:d1f2d829 + m:1122fe24: more Remotion and HyperFrames, ambitious multi-scene, harness runs); concept 'f1_lap_telemetry' (shared by the Remotion and HyperFrames tests); all frames code-drawn; standard remotion harness suffix (30 s); zero results
- plain wave-1-equivalent cc_config copy (settings.json + .claude.json; no ECC files)
- W2 remotion skills installed in this run's cc_config/skills
- W2: the framework's pinned node_modules is bound read-only at work/node_modules (the prompt's 'pre-installed and read-only'); Node 22.23.3 and work/node_modules/.bin first on PATH; headless Chromium /usr/bin/chromium
- Mode: interactive TUI in tmux (160x48), inside bubblewrap sandbox
- Context setting: 1M ([1m] model name)
- Isolation audit: none